12%
Improved throughput
95%
Robot utilization
BACKGROUND
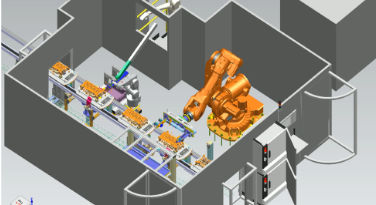
A leading automotive component manufacturer planned to increase throughput of its existing cylinder head cleaning line by introducing one more robot for additional cleaning operations. We performed digital simulation to validate reachability, check for clashes and verify optimal line performance (OLP) before physically implementing a newly introduced robot.
CHALLENGE
- Ensuring Reachability
- Clash-Free Operation
- Optimal Line Performance
APPROACH
- Created accurate 3D model of the existing line and new robot
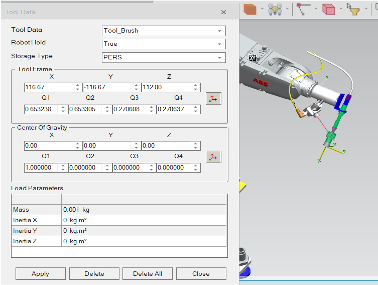
- Performed reachability analysis for all target points on the cylinder head
- Conducted clash detection with robots, fixtures, conveyors and guarding
- Evaluated line cycle time and robot utilization for OLP
- Fine-tuned robot position and sequence to ensure smooth operation